Christian Remmelberger

Portfolio

Christian Remmelberger

M.Sc. Computer Science student at ETH Zurich (Machine Intelligence). Focusing on the intersection of Robotics, AI, and Human-Machine Interaction, currently exploring teleoperation and learning for dexterous robotic hands. Formerly at Microsoft and Agile Robots.

About

Education & Research Focus

M.Sc. Computer Science student at ETH Zurich, majoring in Machine Intelligence. B.Sc. from TUM with the best.in.tum excellence scholarship and a thesis on teleoperation for tactile fine manipulation. Exchange semester at UC San Diego. Research interests in robotic manipulation, AI, and humanoids.

Professional Experience

Humanoid R&D intern at Agile Robots, prototyping a new dexterous robotic hand. Student Researcher at the TUM Chair of Learning AI, building teleoperation systems for dexterous robot hands. Former intern at Microsoft (deepfake detection & signal analysis).

Projects & Initiatives

Founded and led EyeVoices, an eye-blink-based communication platform for people with severe paralysis. Team lead of the Claw team at RoboTUM, building dexterous robotic hands and training policies with LeRobot. Working primarily with Python, C++, and PyTorch.

Selected Projects

Bachelor Thesis: Glove Teleoperation of a Simulated Robotic Hand

Bachelor Thesis: Glove Teleoperation of a Simulated Robotic Hand

Built a teleoperation pipeline that maps Manus glove data onto a four-finger robotic hand in MuJoCo, compared joint-space and IK-based retargeting, and visualized fingertip contact forces as visual feedback.

Imitation Learning with a Franka FR3 and the RoboTUM Claw

Collected demonstrations with a Franka FR3 and our RoboTUM Claw hand, teleoperated via GELLO and recorded with LeRobot, and trained a policy that picks up a plush toy and places it on a box.

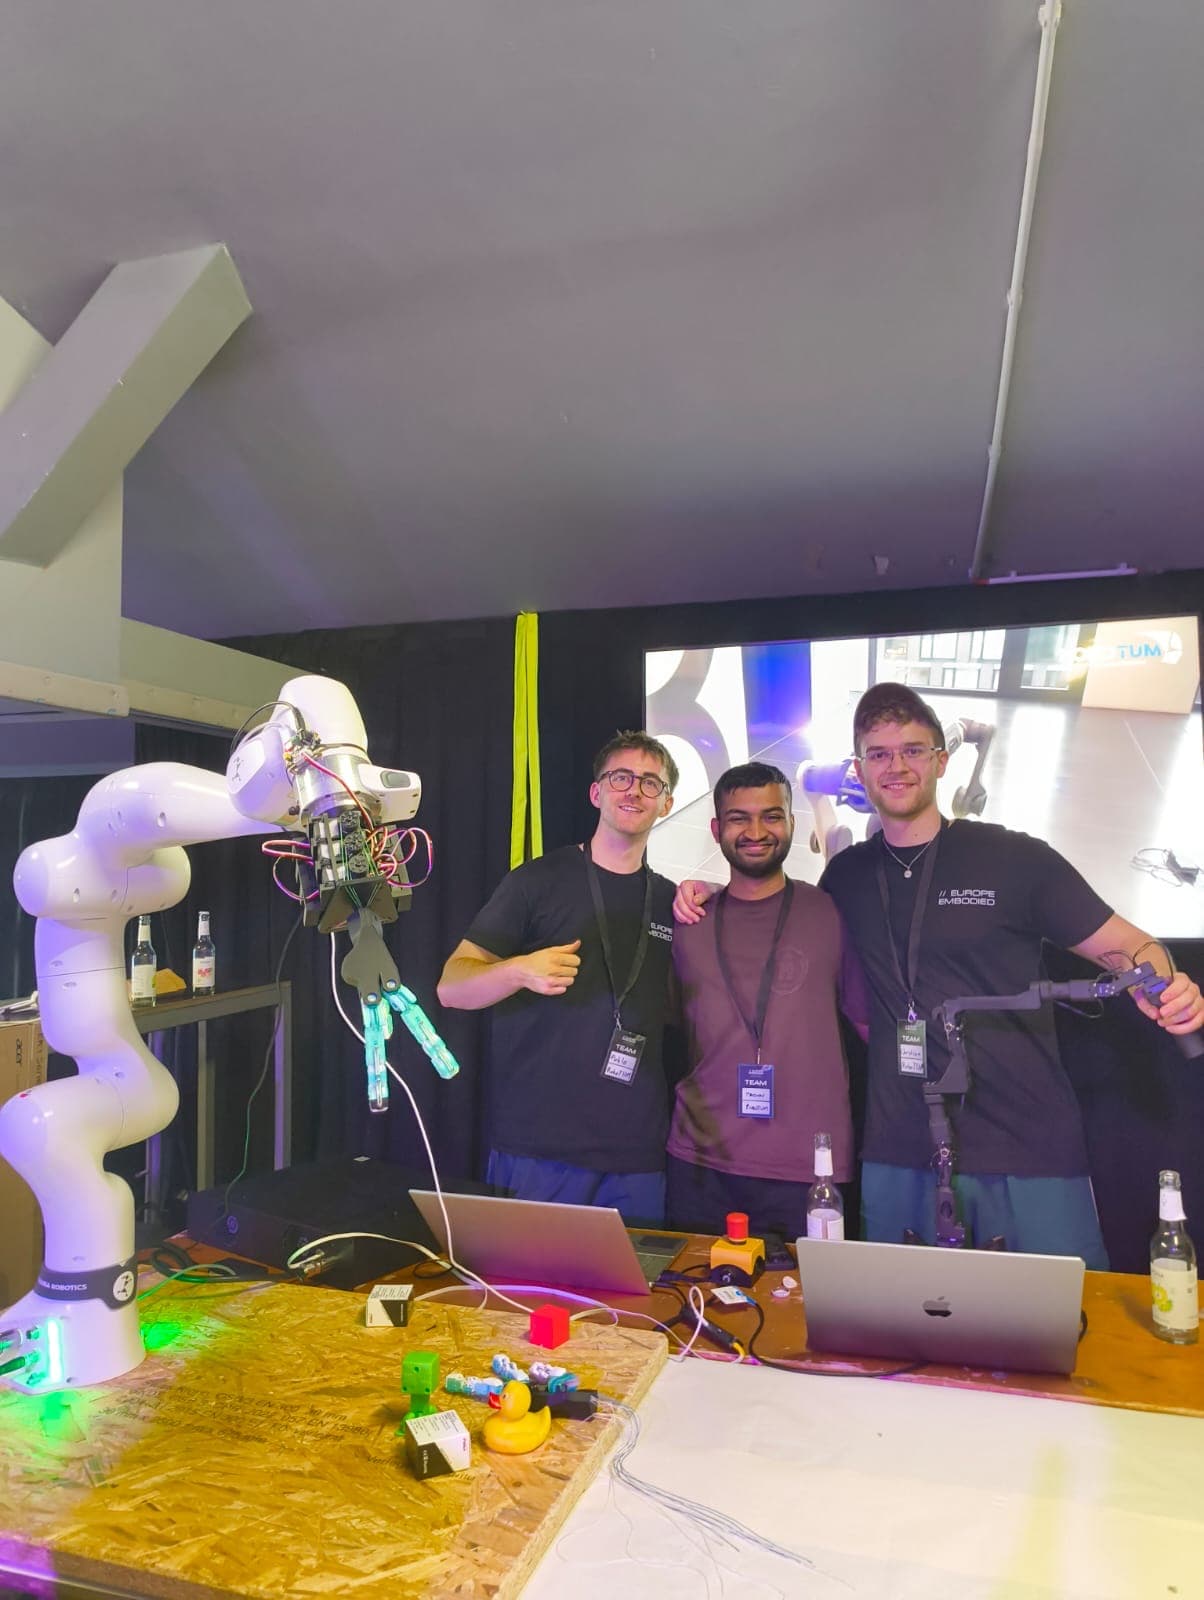
RoboTUM Claw Demo at Europe Embodied 2026

RoboTUM Claw Demo at Europe Embodied 2026

Presented RoboTUM's Claw, an adapted CRAFT hand with fewer fingers, mounted on a teleoperated Franka arm at Europe Embodied, a robotics festival in Munich.

Imitation Learning with LeRobot on the SO-101 Arm

Trained an ACT policy on an SO-101 robot arm with LeRobot to autonomously pick up a cube and place it in a bowl, using only 25 teleoperated demonstrations.

Training a two legged robot at RoboTUM student club

Worked at RoboTUM, a student club at TUM building the fastest two-legged robot in the world, on training the robot in Isaac Lab using reinforcement learning.

EyeVoices

EyeVoices

Founded and led a student initiative developing an assistive communication platform for people with severe paralysis, enabling interaction through eye blinks.

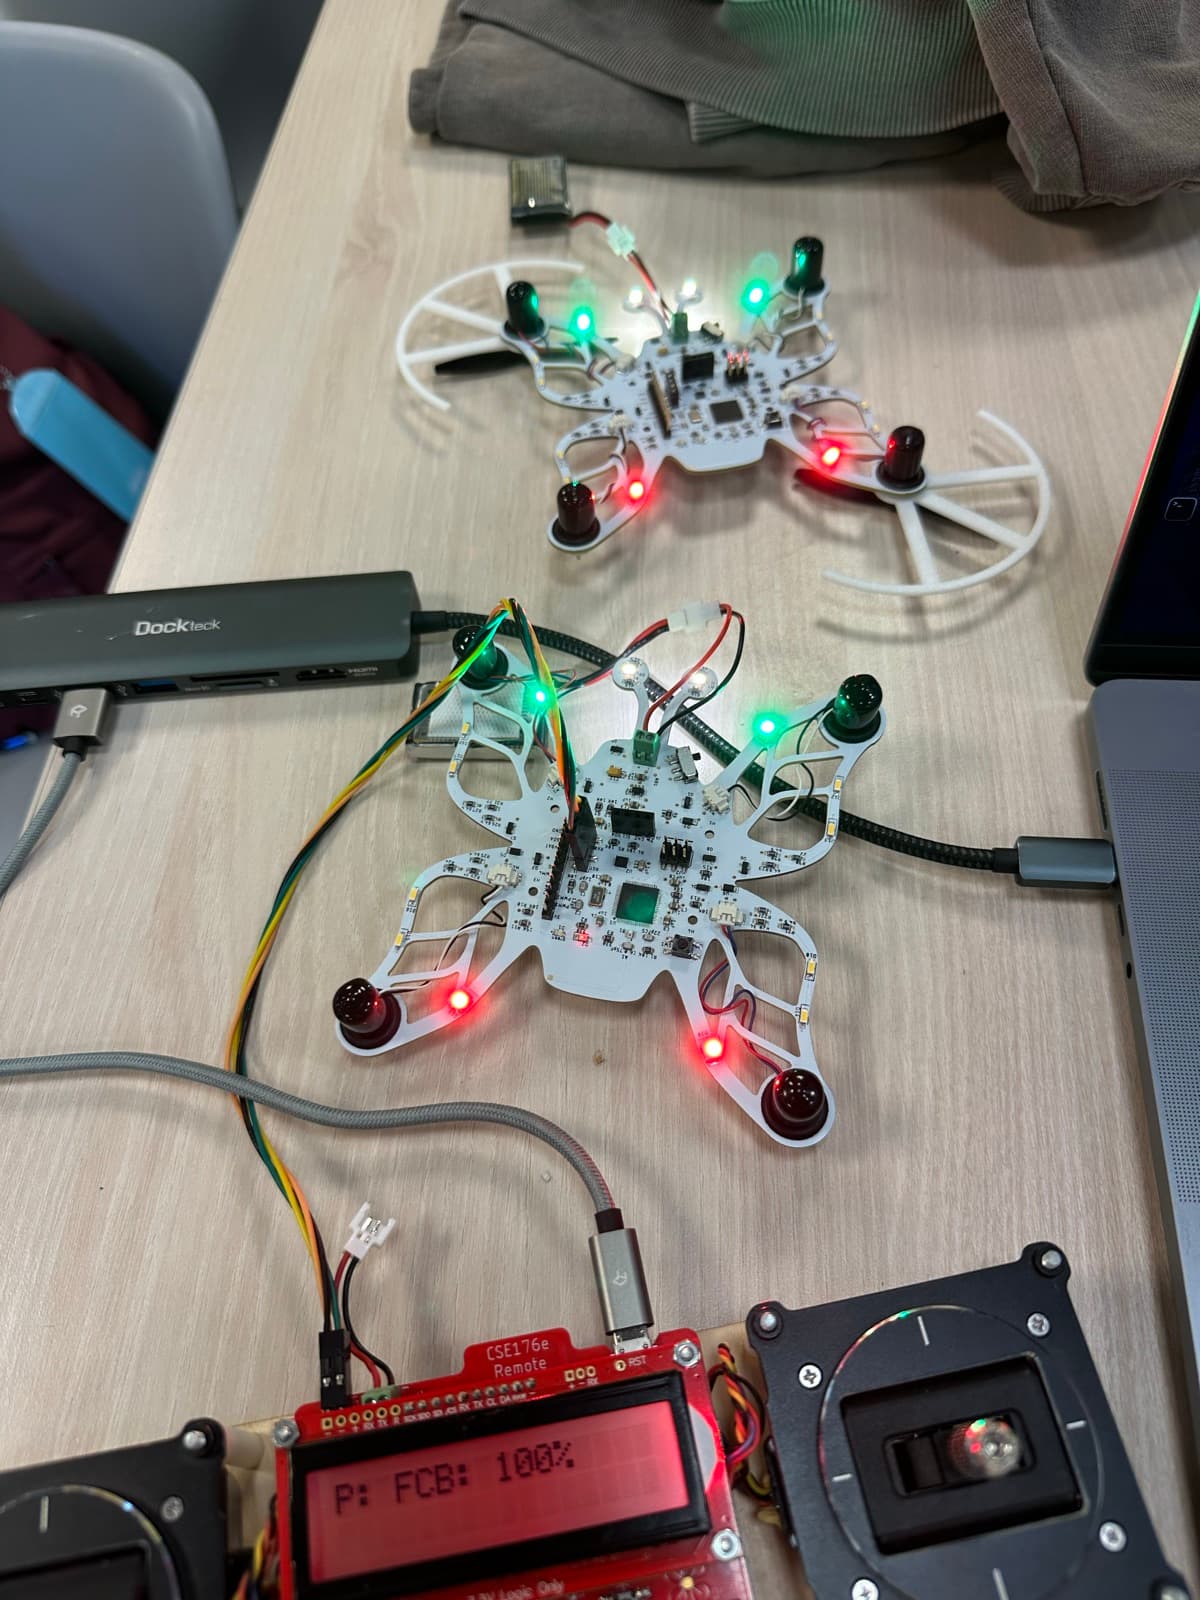
Arduino Quadcopter

Arduino Quadcopter

Designed and programmed a quadcopter and custom remote controller on Arduino, including PID flight control, IMU calibration, and bidirectional communication.

Faculties Football League Website and Management System

Faculties Football League Website and Management System

Built a full-stack web platform (React, Tailwind, Supabase) for managing a student football league with 500+ players. Features include team registration, scheduling, and match planning.

Education

ETH Zurich

M.Sc. Computer Science

Zurich, Switzerland

Sep 2026 — Present

Major in Machine Intelligence. Planned coursework: Robot Dynamics, Planning and Decision Making for Autonomous Robots, Computer Vision, and Probabilistic Artificial Intelligence.

University of California, San Diego (UCSD)

Exchange Semester

San Diego, CA, USA

Sep 2024 — Dec 2024

UPS Extended Studies Program with specialized coursework in Natural Language Processing, Computer Vision, and Robotics.

Technical University of Munich (TUM)

B.Sc. Computer Science

Munich, Germany

Oct 2022 — Aug 2026

Recipient of the best.in.tum excellence scholarship, awarded to the top 2% of the Informatics Department. GPA: 1.3 (best 1.0, pass 4.0, fail 5.0). Thesis: Visual Feedback Induced Teleoperation for Tactile Fine Manipulation with a Robotic Hand.

Work Experience

Agile Robots

Humanoid R&D Intern

Munich, Germany

Jun 2026 — Aug 2026

Contributed to early-stage prototyping of new concepts for a dexterous robotic hand. Set up the initial software stack for the new hand and implemented teleoperation, including hand retargeting with GeoRT.

TUM Chair of Learning AI for Dextrous Robots

Student Researcher

Munich, Germany

Nov 2025 — Aug 2026

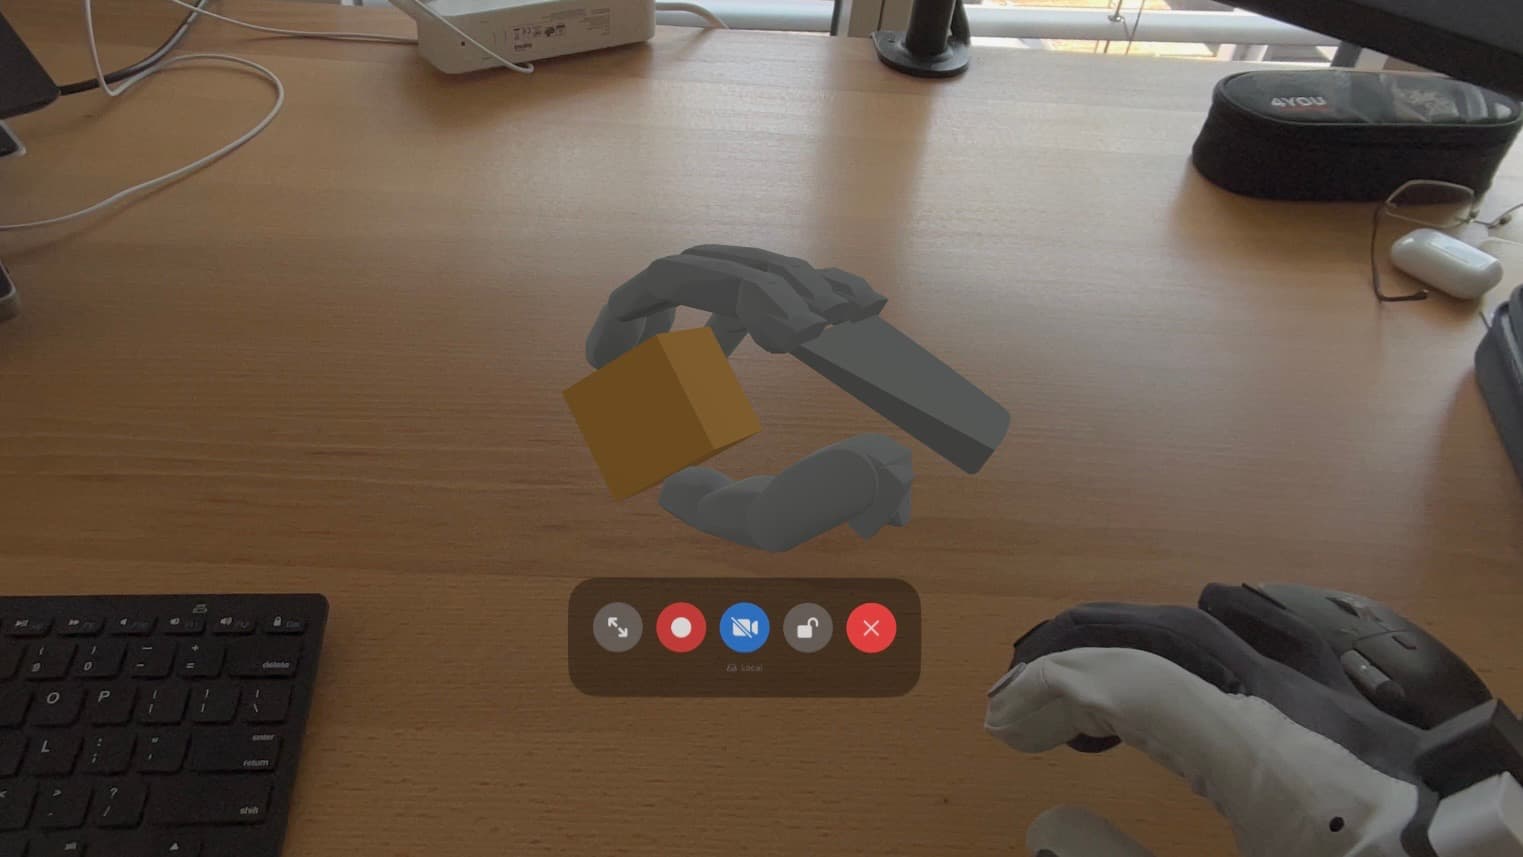
Developed a teleoperation system for a dexterous robot hand. Implemented a learning-based retargeting model that maps human hand motions to the robot's distinct kinematics for precise in-hand manipulation, using Manus Metagloves and immersive MuJoCo simulation on the Apple Vision Pro.

Microsoft

Software Engineering Intern

Dublin, Ireland

Aug 2025 — Oct 2025

Developed honeypot systems to detect and analyze malicious signals within MSTIC. Fine-tuned an EfficientNet-B0 model in PyTorch for deepfake detection. Honorable Mention at Microsoft Global Hackathon for 'Blink+'.

Agile Robots

Robotics Trainee

Munich, Germany

Mar 2024 — Jul 2024

Developed teleoperation software for humanoid robotic systems using Python, C++, and ROS, enabling high-quality demonstration data for downstream VLA and imitation-learning pipelines. Integrated GELLO, haptic gloves, and trackers for precise and responsive manipulation. Delivered live demonstrations to partners and customers.

Contact

I'm always open to discussing new research collaborations, engineering challenges, or interesting opportunities. Reach out at christian.remmelberger@tum.de